7/9

Robotic arm configuration and control

Kinova

Redesigned how users configure and control Kinova's robotic arm, prioritizing key tasks for uses ranging from assistive technology to industry.

Challenge

Kinova needed an easier way to configure and control its robotic arm while supporting a broad range of use cases, from assistive technology to industrial applications.

My contribution

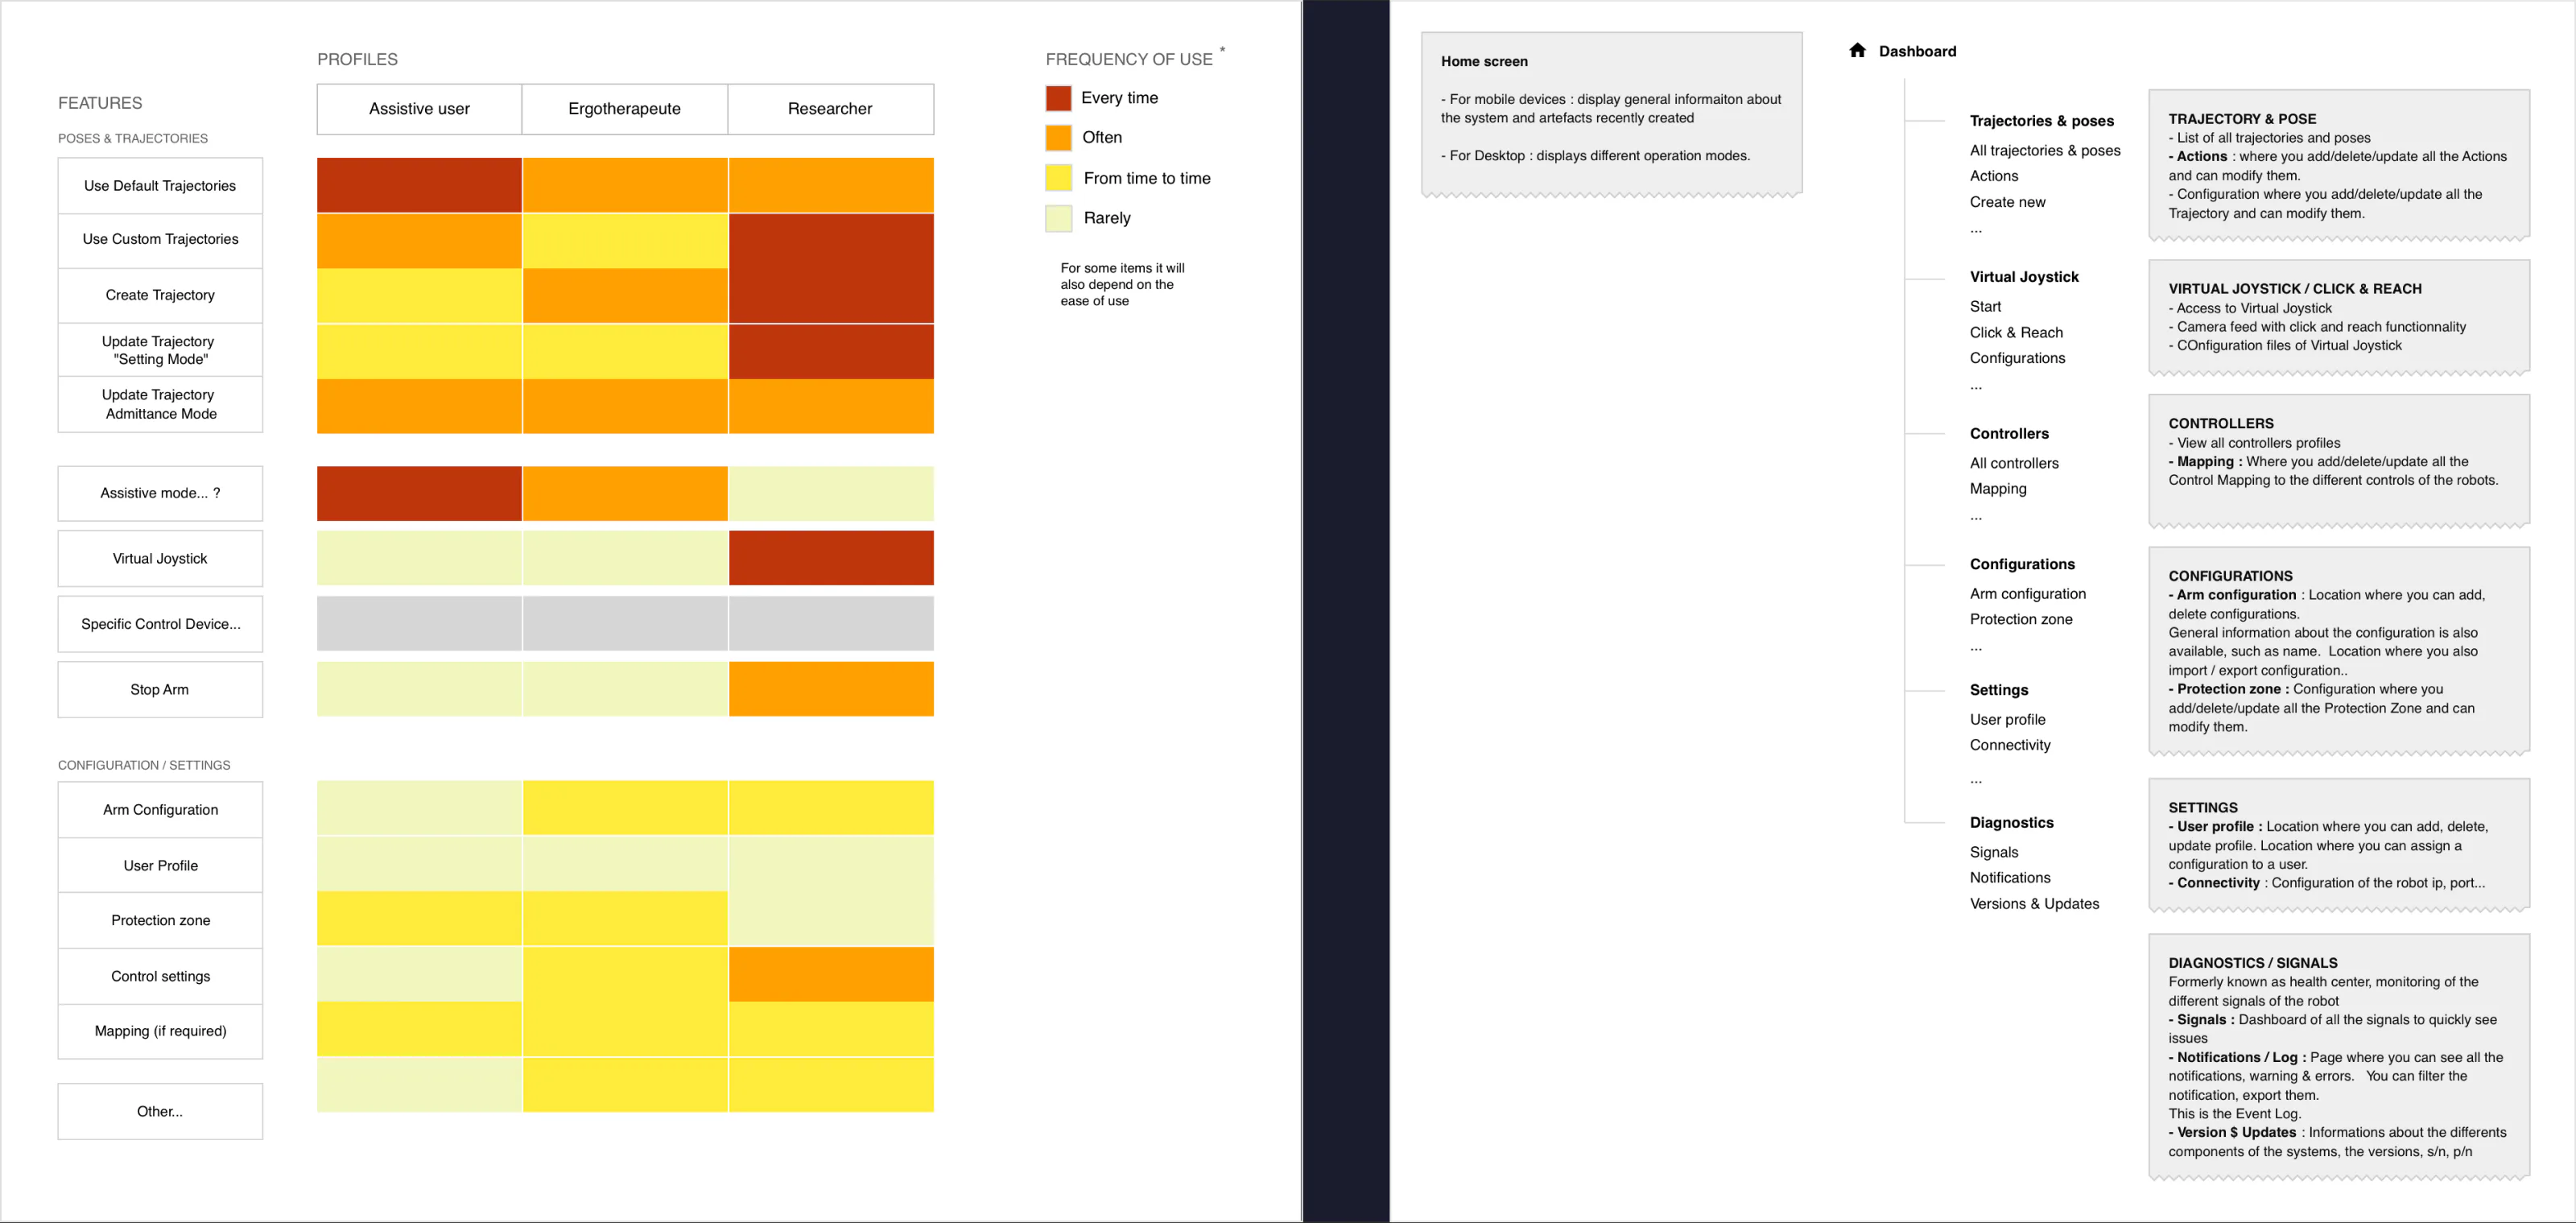
I interviewed stakeholders to analyze needs, prioritized features with the Top Tasks method and aligned everyone on the product vision with high-level wireframes. I then designed the interfaces and data visualizations with the Agile development team.

Results

The web application and new development platform made the robotic arm easier to use across a wider range of applications.

Identifying UX priorities and information architecture
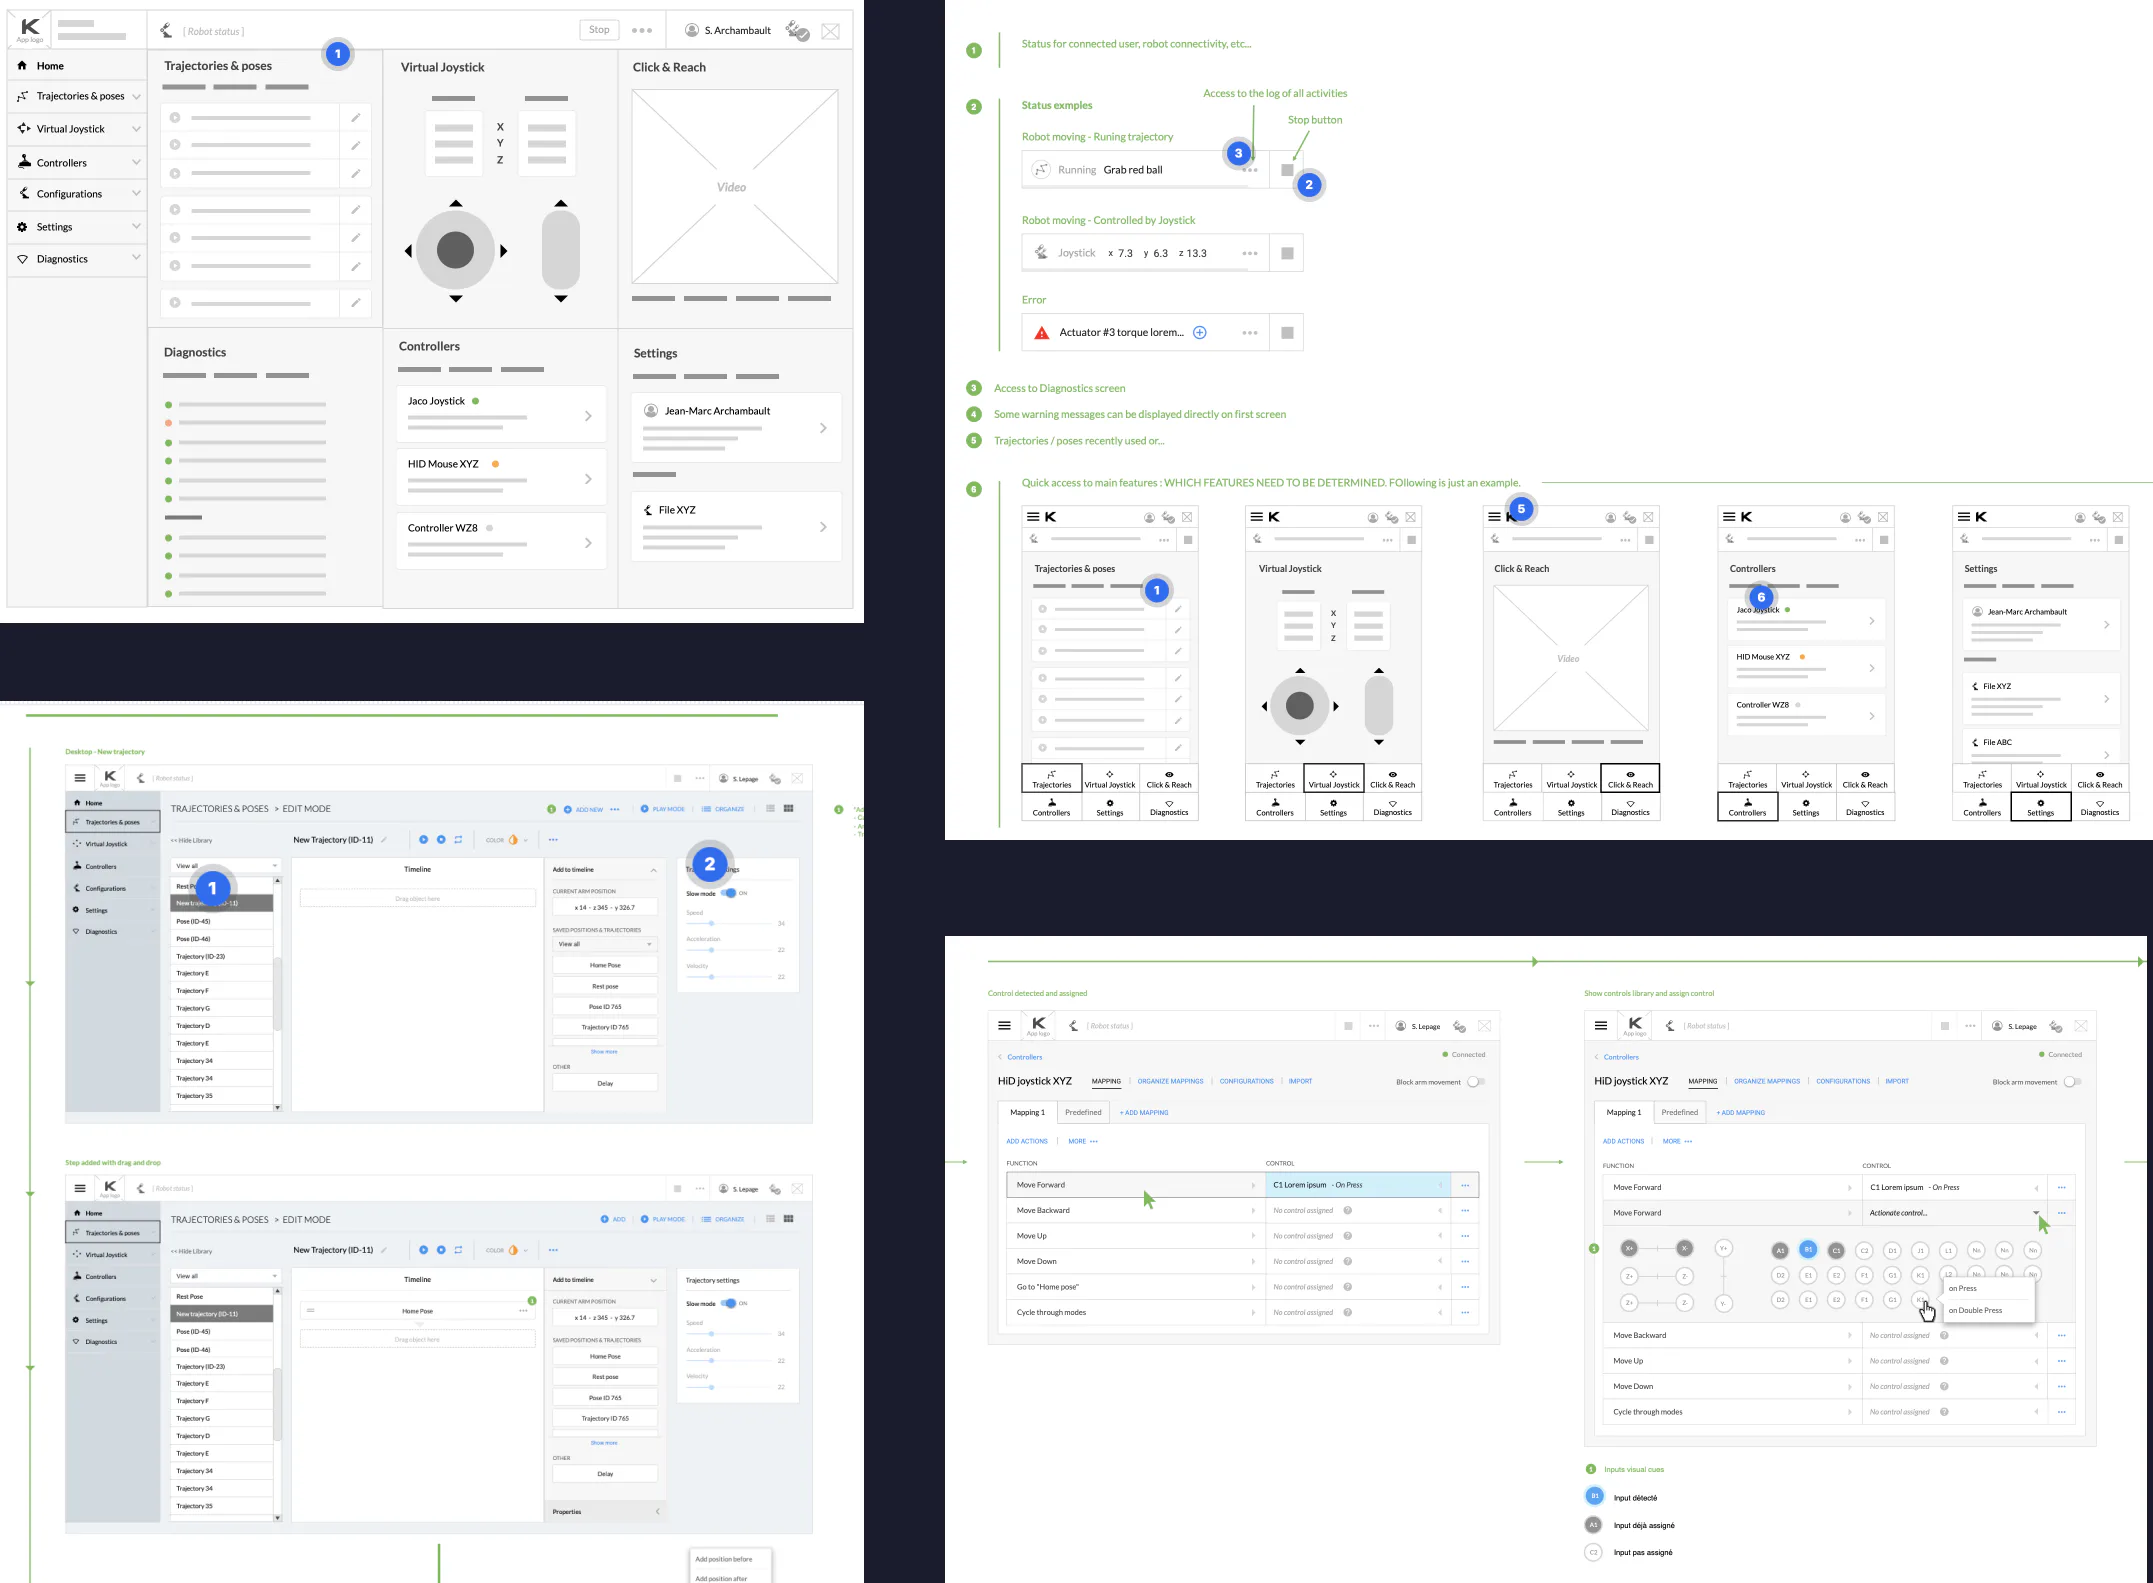
Wireframe examples used to validate the concepts with stakeholders and the team
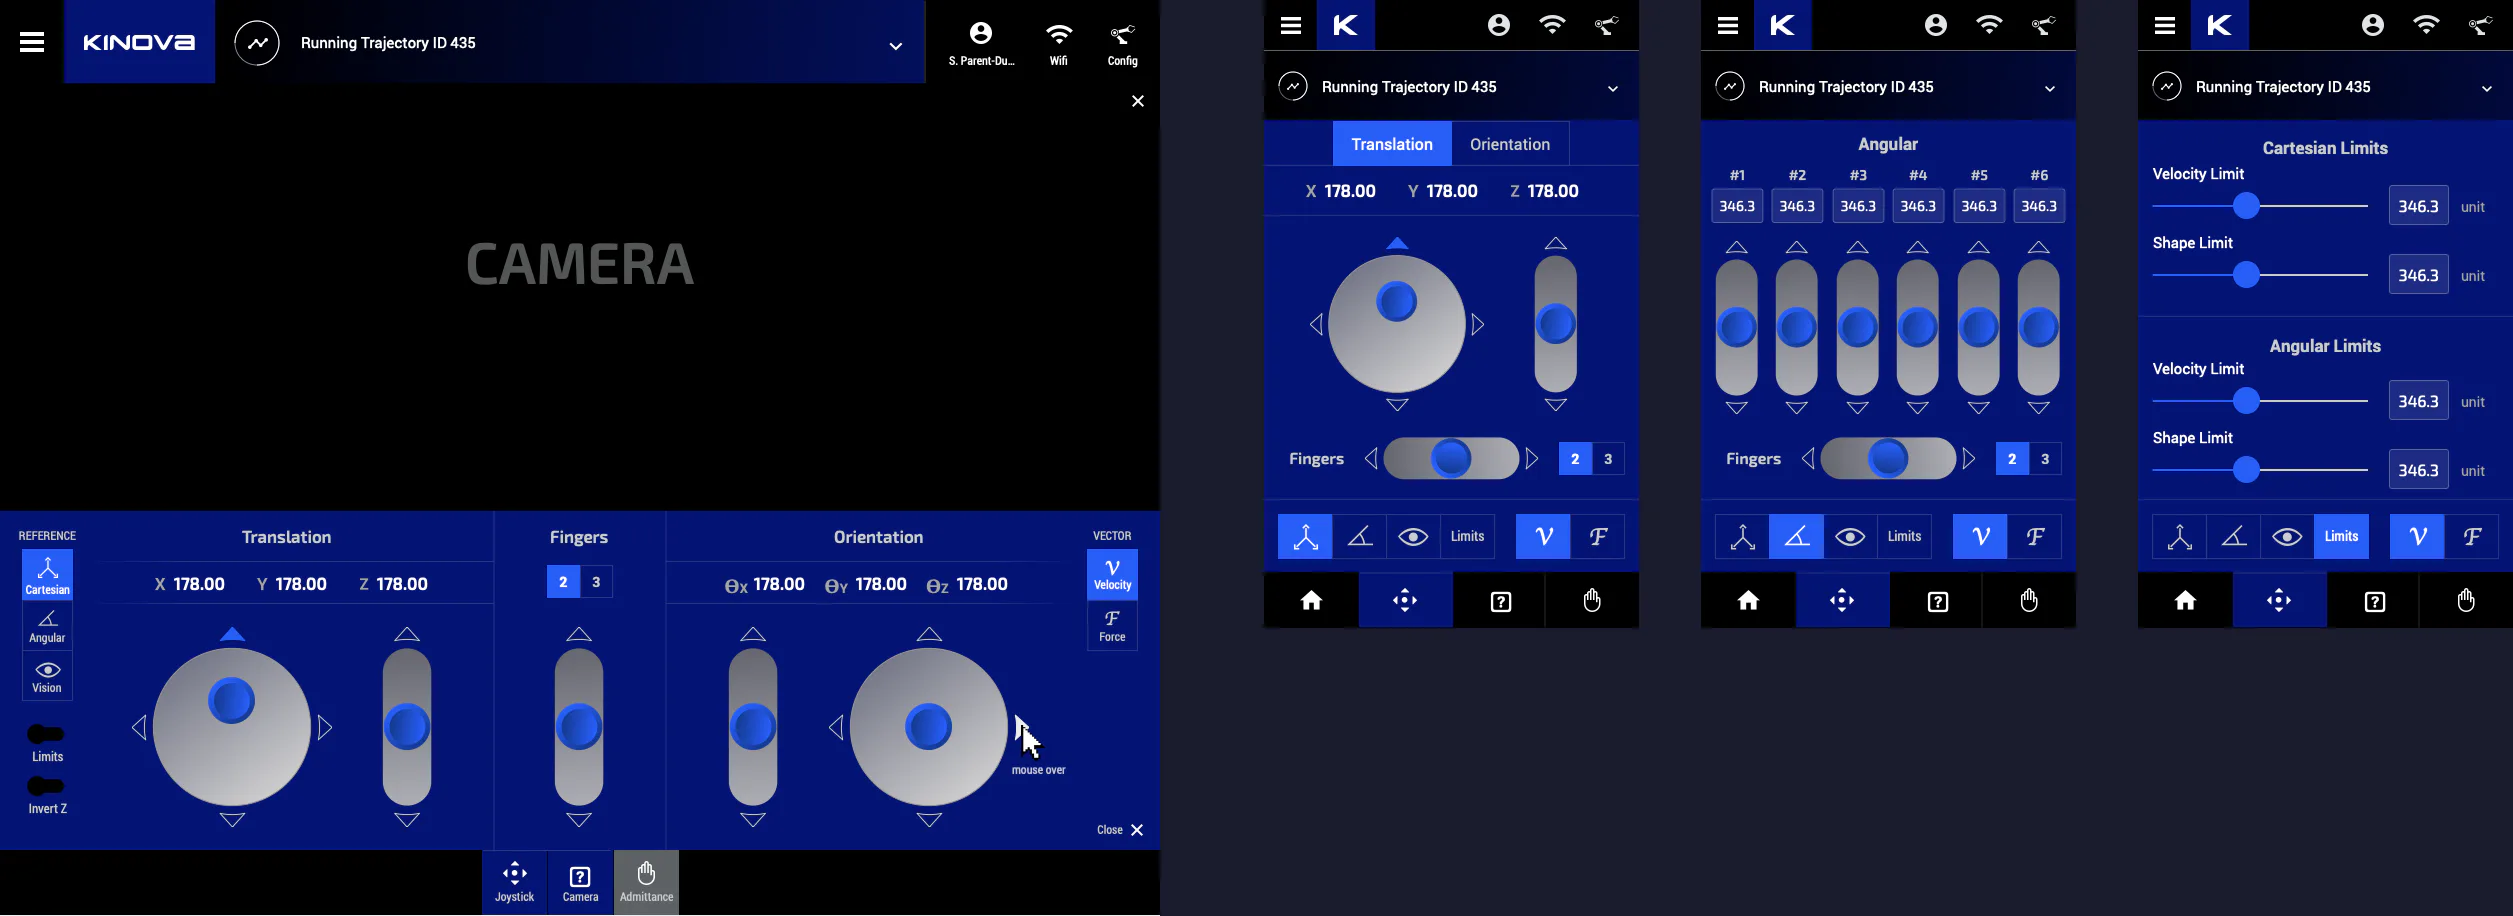
Detailed design: Joystick control
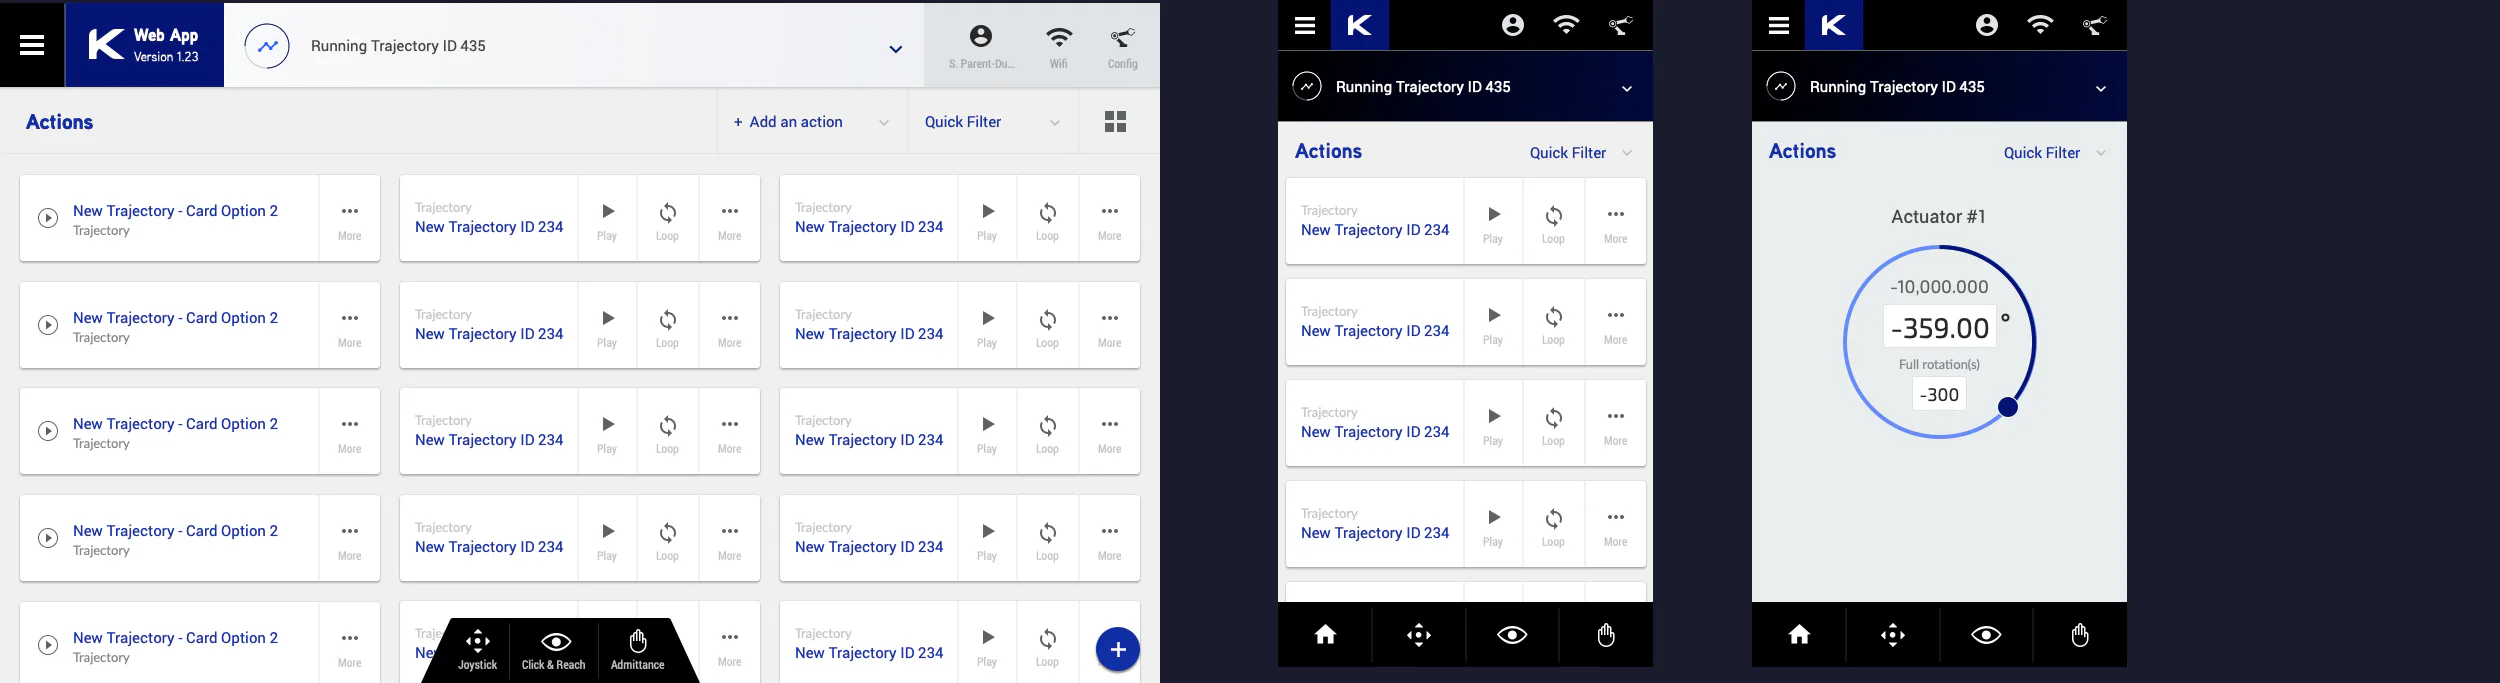
Detailed design: Actions library
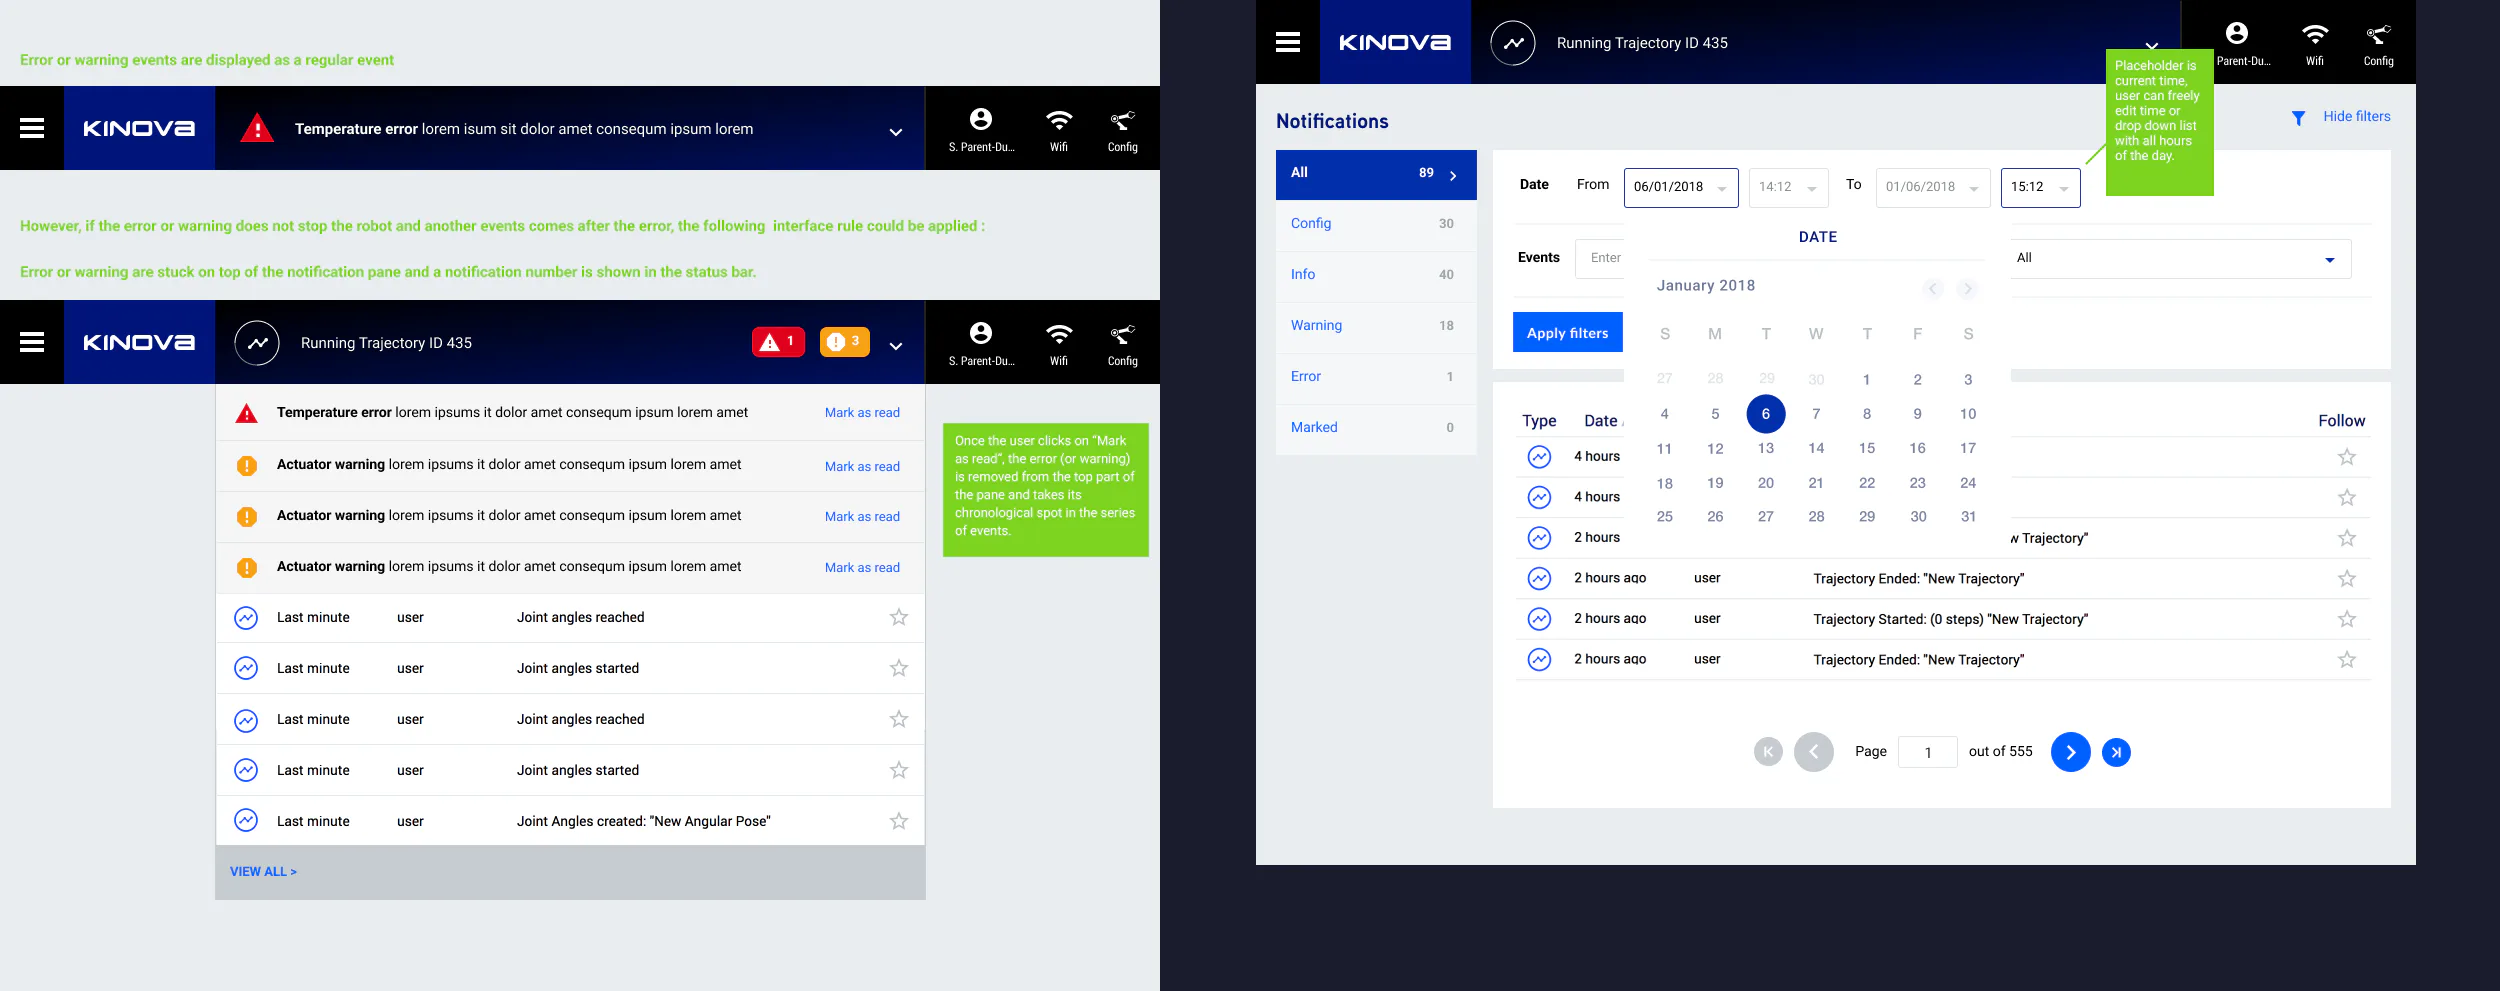
Detailed design: Notification center
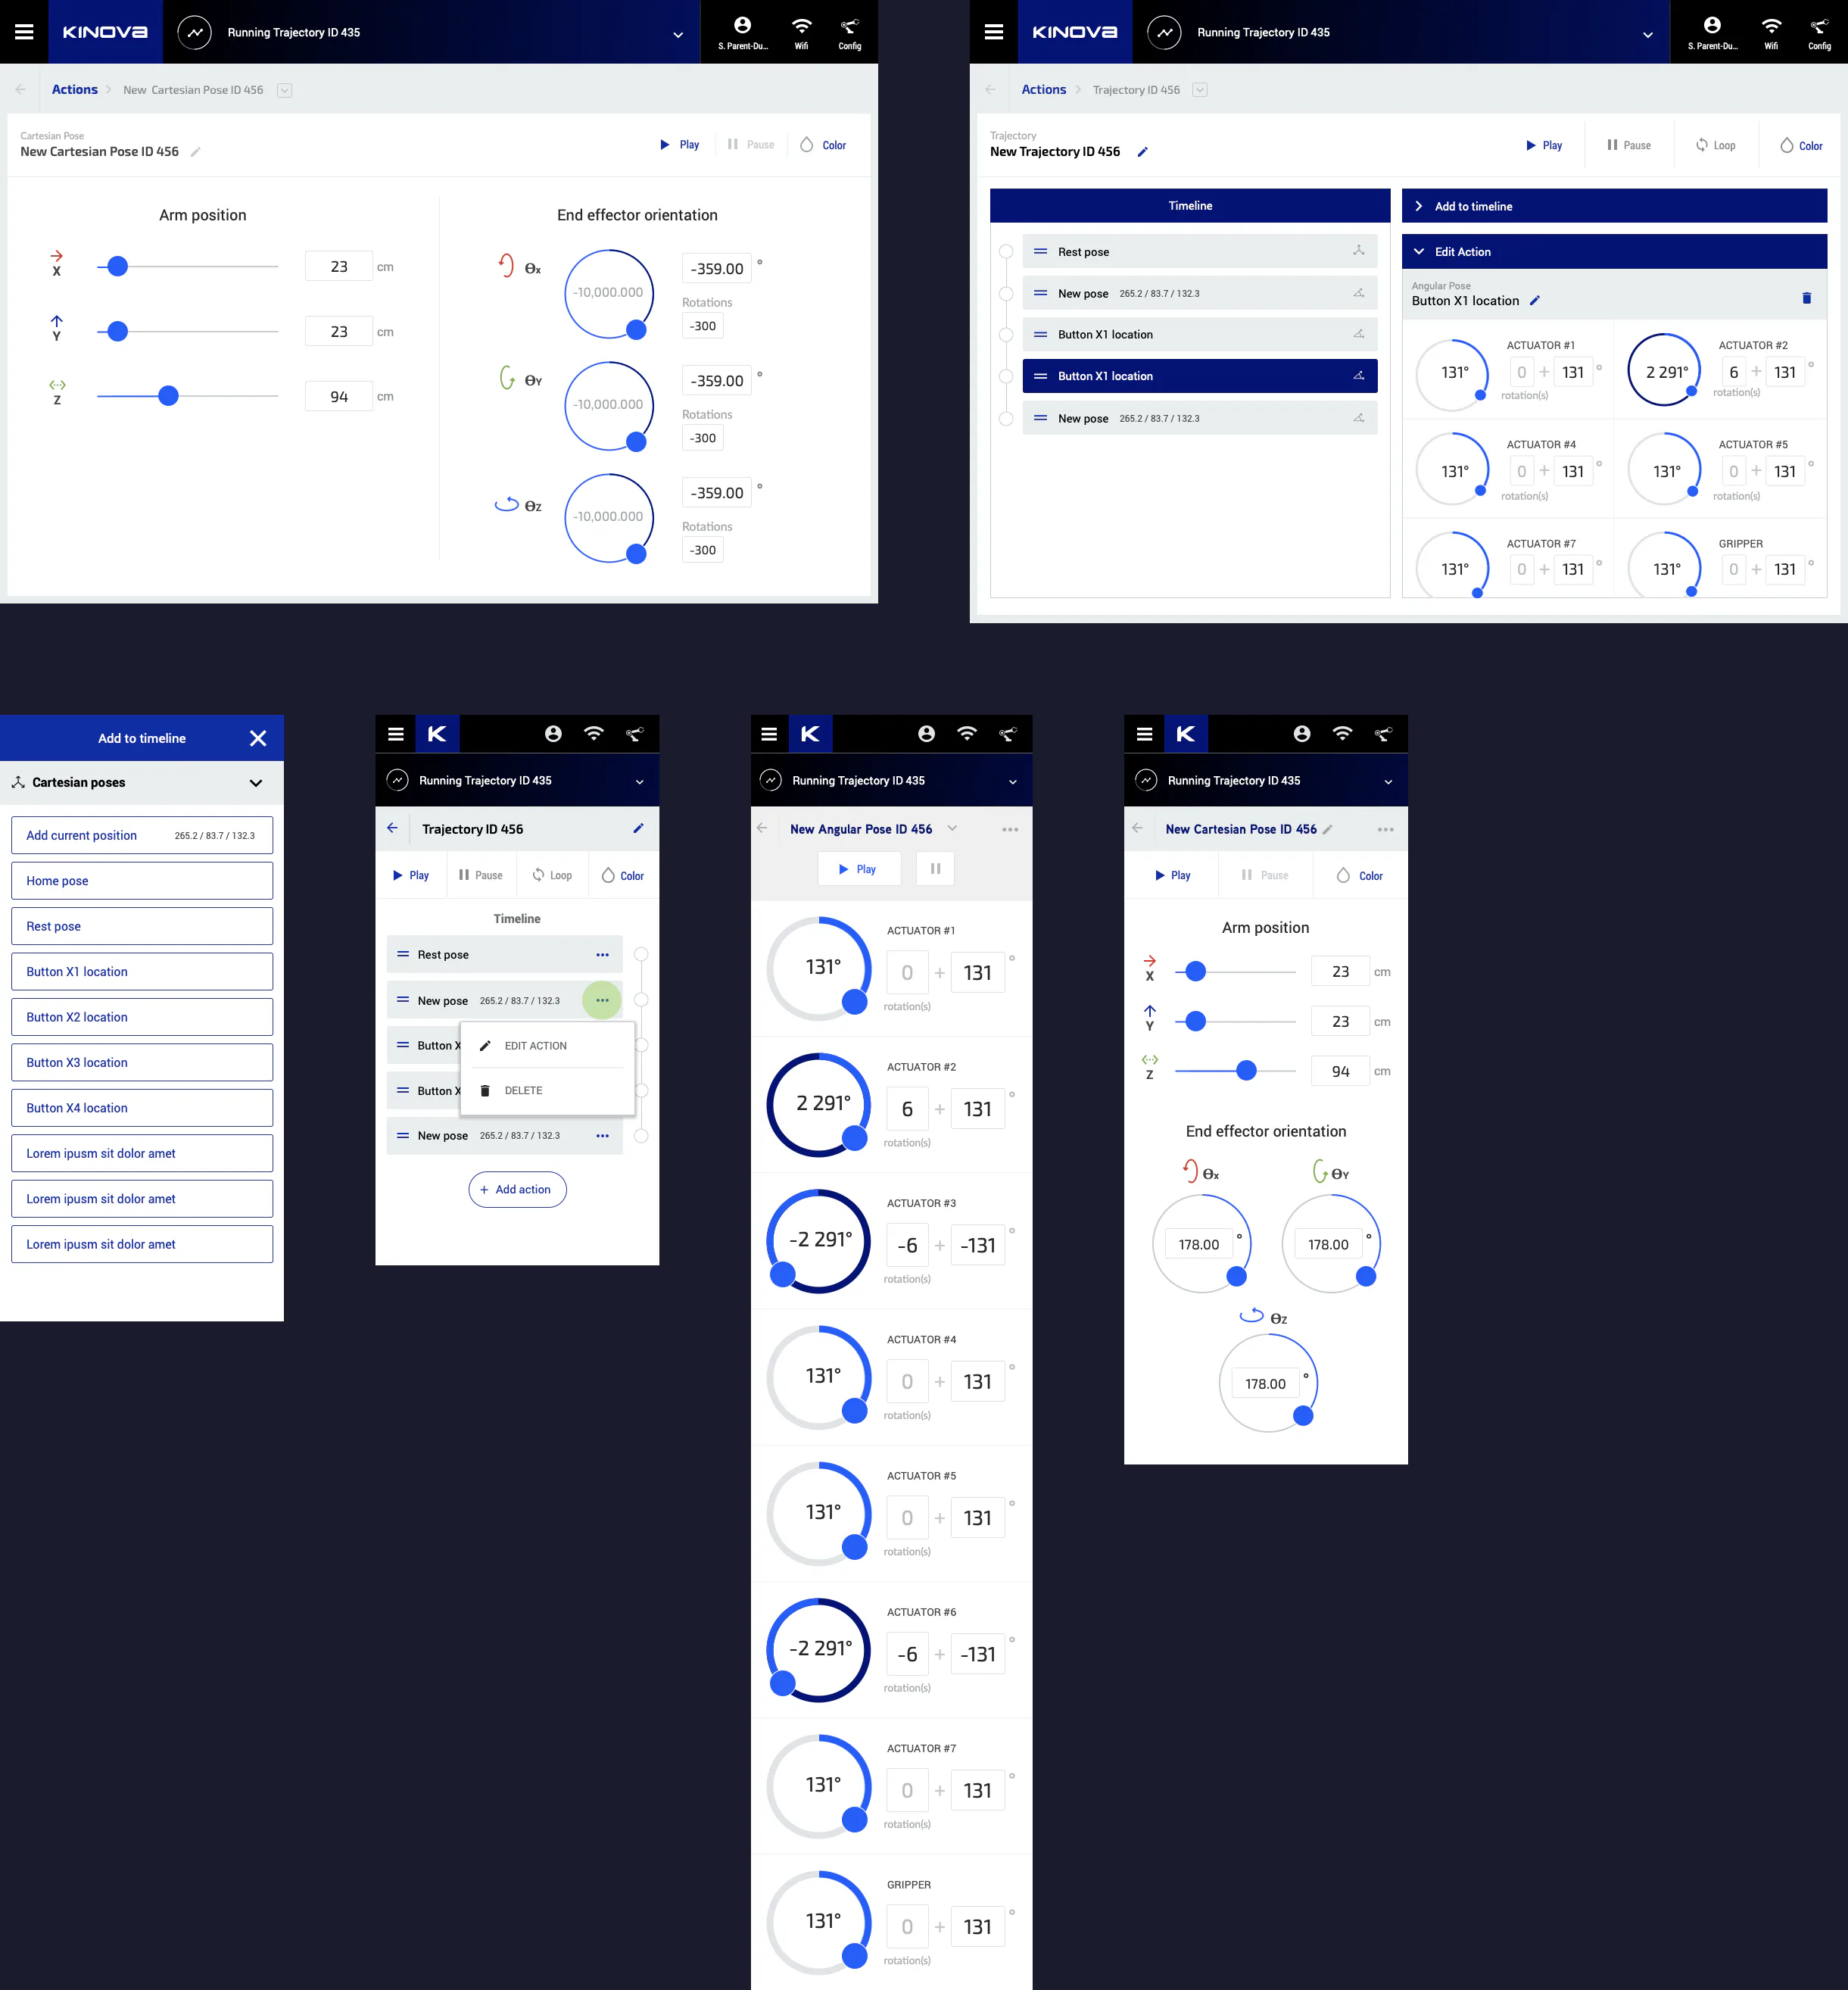
Detailed design: Building poses and trajectories